What's new

DIY Metal Detecting Rover Ready for Testing

halle monkey

Greenie
Joined
Jul 26, 2026
Messages
18
Reaction score
13
Golden Thread
0
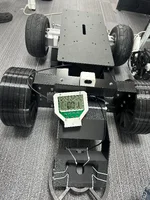
Our DIY metal detecting rover is finally finished in terms of both shape and function, and we are getting ready to start testing.
This is still the first stage, so we expect a lot of issues to show up during the process. We would really like to share ideas, compare notes, and hear any suggestions from members who have worked on similar projects.
If anyone has experience with metal detecting builds, rover platforms, or sensor tuning, we’d love to hear your thoughts.
Thanks for reading, and happy hunting!
 

Attachments

  • 599751926a21c60d7c10e5c83e1b0d82.webp
    599751926a21c60d7c10e5c83e1b0d82.webp
    3 MB · Views: 87
You've been busy. I like the design, it's similar to what I had in mind when I started working on mine, however I found that I suck at programming Arduino and It's a major PITA to tweak the code (IMO).

Just a few thoughts in regard to function...
Is the coil stationary or will it sweep back and forth between the wheels?
Will it to stop over the target and wait for human retrieval, or will it be autonomous?
If autonomous, how do you plan to mark the target location?
 
You've been busy. I like the design, it's similar to what I had in mind when I started working on mine, however I found that I suck at programming Arduino and It's a major PITA to tweak the code (IMO).

Just a few thoughts in regard to function...
Is the coil stationary or will it sweep back and forth between the wheels?
Will it to stop over the target and wait for human retrieval, or will it be autonomous?
If autonomous, how do you plan to mark the target location?
Our coils are fixed, and we expect that the position we mark will make him go to the position we mark, so we should use GPS positioning.
 
  • Like
Reactions: Ism
Our coils are fixed, and we expect that the position we mark will make him go to the position we mark, so we should use GPS positioning.
I reread my post and saw that I wasn't very clear. What I meant by "autonomous" is where the bot would mark a target location with something like non-toxic sports field paint then move on looking for the next target (No need for a remote control).
I think it would be a monumental task to accurately pinpoint a target location. Pinpointing with the bot would probably use up a lot of battery power making the back and forth steering adjustments.
I envision rough location marking that would get you within one foot (or so) of the target where the operator goes back later to find and retrieve.
This robot concept would be cool for wide open fields to search for relics while you chill with friends at a diner, but I would be worried about it not being there when I got back.

Also -Murphy's law, the damn thing will get caught on an obstacle while you are busy elsewhere.

I gave up on the idea when I realized it wouldn't make detecting that much easier for the purposes I had in mind (effort vs reward).
I got motivated for the project once again after seeing the biped humanoid robots available. I think it would be a treat to see one swinging a detector.
However, the cost of a humanoid bot that is designed for R&D purposes (user interfacing) is crazy expensive.

I'm not trying to discourage you, I would love to see you complete your project. You appear to have the proper motivation and skillset.
 
I reread my post and saw that I wasn't very clear. What I meant by "autonomous" is where the bot would mark a target location with something like non-toxic sports field paint then move on looking for the next target (No need for a remote control).
I think it would be a monumental task to accurately pinpoint a target location. Pinpointing with the bot would probably use up a lot of battery power making the back and forth steering adjustments.
I envision rough location marking that would get you within one foot (or so) of the target where the operator goes back later to find and retrieve.
This robot concept would be cool for wide open fields to search for relics while you chill with friends at a diner, but I would be worried about it not being there when I got back.

Also -Murphy's law, the damn thing will get caught on an obstacle while you are busy elsewhere.

I gave up on the idea when I realized it wouldn't make detecting that much easier for the purposes I had in mind (effort vs reward).
I got motivated for the project once again after seeing the biped humanoid robots available. I think it would be a treat to see one swinging a detector.
However, the cost of a humanoid bot that is designed for R&D purposes (user interfacing) is crazy expensive.

I'm not trying to discourage you, I would love to see you complete your project. You appear to have the proper motivation and skillset.
In fact, my idea is that we can use portable RTK for precise positioning, then circle the area on the map, automatically plan the route, and have obstacle avoidance functions. Then, if we detect suspicious metal, it will show a red dot on the map.
 

Users who are viewing this thread

Back
Top Bottom